Loading...
Searching...
No Matches
Hardware YARP devices
YARP devices that provide access to the robot hardware. More...
Collaboration diagram for Hardware YARP devices:
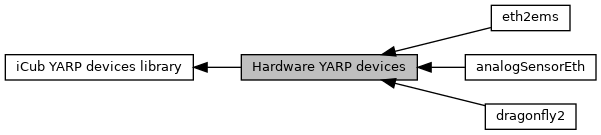
Topics | |
| dragonfly2 | |
| The dragonfly2 framegrabber device driver can acquire RGB color images in 320x240 or 640x480 resolutions. | |
| analogSensorEth | |
| Driver for Ethernet communication with Force-Torque sensors, the Strain2 board. | |
| eth2ems | |
| Implements ICanBus interface < for a ems to can bus device. | |
Classes | |
| class | CanBusAnalogSensor |
| canbusanalogsensor : driver for CAN communication with IIT's analog sensor boards, including the MAIS and STRAIN boards. More... | |
| class | CanBusFtSensor |
| canbusftsensor : driver for CAN communication with IIT's analog sensor boards, including the MAIS and STRAIN boards. More... | |
| class | CanBusInertialMTB |
| canbusinertialmtb : driver for CAN communication with inertial sensors (accelerometers, gyroscopes) mounted on MTB boards. More... | |
| class | yarp::dev::CanBusMotionControl |
| canbusmotioncontrol : driver for motor control boards on a CAN bus. More... | |
| class | ClientCartesianController |
| clientcartesiancontroller : implements the client part of the Cartesian Interface. More... | |
| class | ServerCartesianController |
| servercartesiancontroller : implements the server part of the Cartesian Interface. More... | |
| class | yarp::dev::Cfw2Can |
| cfw2can : driver implementing the yarp::dev::ICanBus interface for a cfw2 can bus device (cfw2 pc104 card). More... | |
| class | yarp::dev::DragonflyDeviceDriver2Rgb |
| dragonfly2 : framegrabber device driver that can acquire RGB color images in 320x240 or 640x480 resolutions. More... | |
| class | yarp::dev::DragonflyDeviceDriver2Raw |
| dragonfly2raw : framegrabber device driver that can acquire raw format images in 640x480 resolution. More... | |
| class | yarp::dev::embObjMotionControl |
| embObjMotionControl : driver for iCub motor control boards EMS on a ETH bus. More... | |
| class | yarp::dev::EsdCan |
| ecan : implements yarp::dev::ICanBus for a esd can bus board. More... | |
| class | yarp::dev::FakeCan |
| fakecan : implements yarp::dev::ICanBus for a software (fake) can bus board. More... | |
| class | ClientGazeController |
| clientgazecontroller : implements the client part of the the Gaze Control Interface. More... | |
| class | yarp::dev::imuST_M1 |
| imuST_M1 : driver for 3DM_GX3 IMU unit from MicroStrain More... | |
| class | yarp::dev::PlxCan |
| pcan : implements yarp::dev::ICanBus for a "plx based" can bus device (cfw pc104 card). More... | |
| class | yarp::dev::CanBusAccessPoint |
| sharedcan : implements ICanBus interface for multiple access from a single access can driver (for example cfw2can). More... | |
| class | yarp::dev::SocketCan |
| socketcan : implements yarp::dev::ICanBus for a linux socketcan. More... | |
| class | yarp::dev::XSensMTx |
| xsensmtx : driver for XSens's MTx IMU unit. More... | |
Detailed Description
YARP devices that provide access to the robot hardware.
To add a device to this list please add this in the source code:
  /**
   * @ingroup icub_hardware_modules
   * @brief `yarpdevicename` : device description.
   *
   */
(This page can be edited at src/doc/groups.dox)
Generated on for iCub-main by
 1.15.0