canbusinertialmtb : driver for CAN communication with inertial sensors (accelerometers, gyroscopes) mounted on MTB boards. More...
#include <CanBusInertialMTB.h>
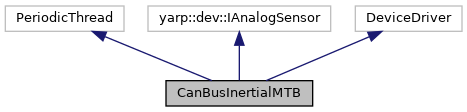
Public Member Functions | |
| CanBusInertialMTB (int period=20) | |
| ~CanBusInertialMTB () | |
| virtual bool | open (yarp::os::Searchable &config) |
| virtual bool | close () |
| virtual int | read (yarp::sig::Vector &out) |
| virtual int | getState (int ch) |
| virtual int | getChannels () |
| int | calibrateSensor () |
| virtual int | calibrateChannel (int ch, double v) |
| virtual int | calibrateSensor (const yarp::sig::Vector &v) |
| virtual int | calibrateChannel (int ch) |
| virtual bool | threadInit () |
| virtual void | threadRelease () |
| virtual void | run () |
Protected Attributes | |
| PolyDriver | driver |
| ICanBus * | pCanBus |
| ICanBufferFactory * | pCanBufferFactory |
| CanBuffer | inBuffer |
| CanBuffer | outBuffer |
| std::mutex | mtx |
| std::vector< MTBInertialBoardInfo > | boards |
| int | nrOfTotalChannels |
| yarp::sig::Vector | data |
| yarp::sig::Vector | privateData |
| std::vector< short > | sharedStatus |
| std::vector< short > | privateStatus |
| short | sharedGlobalStatus |
| short | privateGlobalStatus |
| bool | initted |
| int | count |
Detailed Description
canbusinertialmtb : driver for CAN communication with inertial sensors (accelerometers, gyroscopes) mounted on MTB boards.
The minimum MTB firmware version supported by this device is 2.10.17 .
It is possible to read from multiple MTB. This readings will be combined in a single vector.
| YARP device name |
|---|
| canbusinertialmtb |
Parameters accepted in the config argument of the open method:
| Parameter name | Type | Units | Default Value | Required | Description | Notes |
|---|---|---|---|---|---|---|
| canbusDevice | string | - | - | Yes | Yarp device name of CAN Bus wrapper | - |
| physDevice | string | - | - | Yes | Yarp device name for the low level CAN device driver | - |
| canDeviceNum | int | - | - | Yes | ID of the CAN Bus line | - |
| canAddress | vector of int | - | - | Yes | Vector of the CAN Bus Addresses for the sensor boards | - |
| period | int | milliseconds | 10 | No | Period of the thread reading messages from the CAN bus | - |
| sensorType | int | - | Yes | Type of sensor to read from MTBs. | Possible values: acc for the internal LIS331DLH accelerometer of the MTB, extAccAndGyro for the external LIS331DLH accelerometer and L3G4200D gyroscope. | |
| sensorPeriod | int | milliseconds | 5 | No | Every sensorPeriod milliseconds the MTB publishes the sensor measurements on the CAN Bus | Possible values: from 1 to 255 |
Definition at line 60 of file CanBusInertialMTB.h.
Constructor & Destructor Documentation
◆ CanBusInertialMTB()
|
inline |
Definition at line 97 of file CanBusInertialMTB.h.
◆ ~CanBusInertialMTB()
|
inline |
Definition at line 103 of file CanBusInertialMTB.h.
Member Function Documentation
◆ calibrateChannel() [1/2]
|
virtual |
Definition at line 307 of file CanBusInertialMTB.cpp.
◆ calibrateChannel() [2/2]
|
virtual |
Definition at line 295 of file CanBusInertialMTB.cpp.
◆ calibrateSensor() [1/2]
| int CanBusInertialMTB::calibrateSensor | ( | ) |
Definition at line 289 of file CanBusInertialMTB.cpp.
◆ calibrateSensor() [2/2]
|
virtual |
Definition at line 301 of file CanBusInertialMTB.cpp.
◆ close()
|
virtual |
Definition at line 255 of file CanBusInertialMTB.cpp.
◆ getChannels()
|
virtual |
Definition at line 284 of file CanBusInertialMTB.cpp.
◆ getState()
|
virtual |
Definition at line 278 of file CanBusInertialMTB.cpp.
◆ open()
|
virtual |
Definition at line 135 of file CanBusInertialMTB.cpp.
◆ read()
|
virtual |
Definition at line 271 of file CanBusInertialMTB.cpp.
◆ run()
|
virtual |
Definition at line 369 of file CanBusInertialMTB.cpp.
◆ threadInit()
|
virtual |
Definition at line 313 of file CanBusInertialMTB.cpp.
◆ threadRelease()
|
virtual |
Definition at line 489 of file CanBusInertialMTB.cpp.
Member Data Documentation
◆ boards
|
protected |
Definition at line 83 of file CanBusInertialMTB.h.
◆ count
|
protected |
Definition at line 95 of file CanBusInertialMTB.h.
◆ data
|
protected |
Definition at line 87 of file CanBusInertialMTB.h.
◆ driver
|
protected |
Definition at line 75 of file CanBusInertialMTB.h.
◆ inBuffer
|
protected |
Definition at line 78 of file CanBusInertialMTB.h.
◆ initted
|
protected |
Definition at line 94 of file CanBusInertialMTB.h.
◆ mtx
|
protected |
Definition at line 81 of file CanBusInertialMTB.h.
◆ nrOfTotalChannels
|
protected |
Definition at line 85 of file CanBusInertialMTB.h.
◆ outBuffer
|
protected |
Definition at line 79 of file CanBusInertialMTB.h.
◆ pCanBufferFactory
|
protected |
Definition at line 77 of file CanBusInertialMTB.h.
◆ pCanBus
|
protected |
Definition at line 76 of file CanBusInertialMTB.h.
◆ privateData
|
protected |
Definition at line 88 of file CanBusInertialMTB.h.
◆ privateGlobalStatus
|
protected |
Definition at line 92 of file CanBusInertialMTB.h.
◆ privateStatus
|
protected |
Definition at line 90 of file CanBusInertialMTB.h.
◆ sharedGlobalStatus
|
protected |
Definition at line 91 of file CanBusInertialMTB.h.
◆ sharedStatus
|
protected |
Definition at line 89 of file CanBusInertialMTB.h.
The documentation for this class was generated from the following files:
- icub-main/src/libraries/icubmod/canBusInertialMTB/CanBusInertialMTB.h
- icub-main/src/libraries/icubmod/canBusInertialMTB/CanBusInertialMTB.cpp
Generated on for iCub-main by
 1.15.0