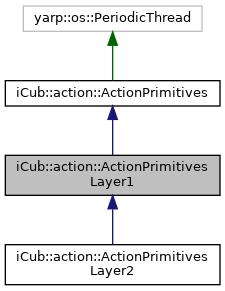
A derived class defining a first abstraction layer on top of actionPrimitives father class. More...
#include <actionPrimitives.h>
Public Member Functions | |
| ActionPrimitivesLayer1 () | |
| Default Constructor. | |
| ActionPrimitivesLayer1 (yarp::os::Property &opt) | |
| Constructor. | |
| virtual bool | grasp (const yarp::sig::Vector &x, const yarp::sig::Vector &o, const yarp::sig::Vector &d) |
| Grasp the given target (combined action). | |
| virtual bool | touch (const yarp::sig::Vector &x, const yarp::sig::Vector &o, const yarp::sig::Vector &d) |
| Touch the given target (combined action). | |
| virtual bool | tap (const yarp::sig::Vector &x1, const yarp::sig::Vector &o1, const yarp::sig::Vector &x2, const yarp::sig::Vector &o2, const double execTime=ACTIONPRIM_DISABLE_EXECTIME) |
| Tap the given target (combined action). | |
| Public Member Functions inherited from iCub::action::ActionPrimitives | |
| ActionPrimitives () | |
| Default Constructor. | |
| ActionPrimitives (yarp::os::Property &opt) | |
| Constructor. | |
| virtual | ~ActionPrimitives () |
| Destructor. | |
| virtual bool | open (yarp::os::Property &opt) |
| Configure the object. | |
| virtual bool | isValid () const |
| Check if the object is initialized correctly. | |
| virtual void | close () |
| Deallocate the object. | |
| virtual bool | pushAction (const yarp::sig::Vector &x, const yarp::sig::Vector &o, const std::string &handSeqKey, const double execTime=ACTIONPRIM_DISABLE_EXECTIME, ActionPrimitivesCallback *clb=NULL) |
| Insert a combination of arm and hand primitive actions in the actions queue. | |
| virtual bool | pushAction (const yarp::sig::Vector &x, const std::string &handSeqKey, const double execTime=ACTIONPRIM_DISABLE_EXECTIME, ActionPrimitivesCallback *clb=NULL) |
| Insert a combination of arm and hand primitive actions in the actions queue. | |
| virtual bool | pushAction (const yarp::sig::Vector &x, const yarp::sig::Vector &o, const double execTime=ACTIONPRIM_DISABLE_EXECTIME, ActionPrimitivesCallback *clb=NULL) |
| Insert the arm-primitive action reach for target in the actions queue. | |
| virtual bool | pushAction (const yarp::sig::Vector &x, const double execTime=ACTIONPRIM_DISABLE_EXECTIME, ActionPrimitivesCallback *clb=NULL) |
| Insert the arm-primitive action reach for target in the actions queue. | |
| virtual bool | pushAction (const std::string &handSeqKey, ActionPrimitivesCallback *clb=NULL) |
| Insert a hand-primitive action in the actions queue. | |
| virtual bool | pushAction (const std::deque< ActionPrimitivesWayPoint > &wayPoints, ActionPrimitivesCallback *clb=NULL) |
| Insert in the actions queue a trajectory in the operational space parametrized in terms of waypoints. | |
| virtual bool | pushAction (const std::deque< ActionPrimitivesWayPoint > &wayPoints, const std::string &handSeqKey, ActionPrimitivesCallback *clb=NULL) |
| Insert in the actions queue a combination of hand and arm trajectory in the operational space parametrized in terms of waypoints. | |
| virtual bool | pushWaitState (const double tmo, ActionPrimitivesCallback *clb=NULL) |
| Insert a wait state in the actions queue. | |
| virtual bool | reachPose (const yarp::sig::Vector &x, const yarp::sig::Vector &o, const double execTime=ACTIONPRIM_DISABLE_EXECTIME) |
| Immediately update the current reaching target (without affecting the actions queue) or initiate a new reach (if the actions queue is empty). | |
| virtual bool | reachPosition (const yarp::sig::Vector &x, const double execTime=ACTIONPRIM_DISABLE_EXECTIME) |
| Immediately update the current reaching target (without affecting the actions queue) or initiate a new reach (if the actions queue is empty). | |
| virtual bool | clearActionsQueue () |
| Empty the actions queue. | |
| virtual bool | lockActions () |
| Disable the possibility to yield any new action. | |
| virtual bool | unlockActions () |
| Enable the possibility to yield new actions. | |
| virtual bool | getActionsLockStatus () const |
| Return the actions lock status. | |
| virtual bool | addHandSeqWP (const std::string &handSeqKey, const yarp::sig::Vector &poss, const yarp::sig::Vector &vels, const yarp::sig::Vector &tols, const yarp::sig::Vector &thres, const double tmo) |
| Define an hand WayPoint (WP) to be added at the bottom of the hand motion sequence pointed by the key. | |
| virtual bool | addHandSequence (const std::string &handSeqKey, const yarp::os::Bottle &sequence) |
| Define an hand motion sequence from a configuration bottle. | |
| virtual bool | isValidHandSeq (const std::string &handSeqKey) |
| Check whether a sequence key is defined. | |
| virtual bool | removeHandSeq (const std::string &handSeqKey) |
| Remove an already existing hand motion sequence. | |
| std::deque< std::string > | getHandSeqList () |
| Return the list of available hand sequence keys. | |
| virtual bool | getHandSequence (const std::string &handSeqKey, yarp::os::Bottle &sequence) |
| Return a hand sequence. | |
| virtual bool | areFingersMoving (bool &f) |
| Query if fingers are moving. | |
| virtual bool | areFingersInPosition (bool &f) |
| Query if fingers are in position (cumulative response). | |
| virtual bool | areFingersInPosition (std::deque< bool > &f) |
| Query if fingers are in position (finger-wise response). | |
| virtual bool | getGraspModel (perception::Model *&model) const |
| Return the model used internally to detect external contacts. | |
| virtual bool | getCartesianIF (yarp::dev::ICartesianControl *&ctrl) const |
| Return the cartesian interface used internally to control the limb. | |
| virtual bool | getTorsoJoints (yarp::sig::Vector &torso) |
| Return the control status of torso joints. | |
| virtual bool | setTorsoJoints (const yarp::sig::Vector &torso) |
| Change the control status of torso joints. | |
| virtual bool | getPose (yarp::sig::Vector &x, yarp::sig::Vector &o) const |
| Get the current arm pose. | |
| virtual bool | stopControl () |
| Stop any ongoing arm/hand movements. | |
| virtual bool | setDefaultExecTime (const double execTime) |
| Set the default arm movement execution time. | |
| virtual double | getDefaultExecTime () const |
| Get the current default arm movement execution time. | |
| virtual bool | setTrackingMode (const bool f) |
| Set the task space controller in tracking or non-tracking mode. | |
| virtual bool | getTrackingMode () const |
| Get the current controller mode. | |
| virtual bool | enableArmWaving (const yarp::sig::Vector &restPos) |
| Enable the waving mode that keeps on moving the arm around a predefined position. | |
| virtual bool | disableArmWaving () |
| Disable the waving mode. | |
| virtual bool | enableReachingTimeout (const double tmo) |
| Enable timeout while reaching. | |
| virtual bool | disableReachingTimeout () |
| Disable timeout while reaching. | |
| virtual bool | checkActionsDone (bool &f, const bool sync=false) |
| Check whether all the actions in queue are accomplished. | |
| virtual bool | checkActionOnGoing (bool &f, const bool sync=false) |
| Check whether an action is still ongoing. | |
| virtual bool | syncCheckInterrupt (const bool disable=false) |
| Suddenly interrupt any blocking call that is pending on querying the action status. | |
| virtual bool | syncCheckReinstate () |
| Reinstate the blocking feature for future calls with sync switch on. | |
Additional Inherited Members | |
| Protected Member Functions inherited from iCub::action::ActionPrimitives | |
| virtual void | printMessage (const int logtype, const char *format,...) const |
| virtual bool | handleTorsoDOF (yarp::os::Property &opt, const std::string &key) |
| virtual void | disableTorsoDof () |
| virtual void | enableTorsoDof () |
| virtual bool | configHandSeq (yarp::os::Property &opt) |
| virtual bool | configGraspModel (yarp::os::Property &opt) |
| virtual bool | _pushAction (const bool execArm, const yarp::sig::Vector &x, const yarp::sig::Vector &o, const double execTime, const bool oEnabled, const bool execHand, const HandWayPoint &handWP, const bool handSeqTerminator, ActionPrimitivesCallback *clb) |
| virtual bool | _pushAction (const yarp::sig::Vector &x, const yarp::sig::Vector &o, const std::string &handSeqKey, const double execTime, ActionPrimitivesCallback *clb, const bool oEnabled) |
| virtual bool | handCheckMotionDone (const int jnt) |
| virtual bool | wait (const Action &action) |
| virtual bool | cmdArm (const Action &action) |
| virtual bool | cmdArmWP (const Action &action) |
| virtual bool | cmdHand (const Action &action) |
| virtual bool | isHandSeqEnded () |
| virtual void | postReachCallback () |
| virtual void | init () |
| virtual bool | execQueuedAction () |
| virtual bool | execPendingHandSequences () |
| virtual void | run () |
| Protected Attributes inherited from iCub::action::ActionPrimitives | |
| std::string | robot |
| std::string | local |
| std::string | part |
| yarp::dev::PolyDriver | polyHand |
| yarp::dev::PolyDriver | polyCart |
| yarp::dev::IControlMode * | modCtrl |
| yarp::dev::IEncoders * | encCtrl |
| yarp::dev::IPositionControl * | posCtrl |
| yarp::dev::ICartesianControl * | cartCtrl |
| perception::Model * | graspModel |
| yarp::os::PeriodicThread * | armWaver |
| std::mutex | mtx |
| std::mutex | mtx_motionStartEvent |
| std::condition_variable | cv_motionStartEvent |
| std::mutex | mtx_motionDoneEvent |
| std::condition_variable | cv_motionDoneEvent |
| bool | armMoveDone |
| bool | handMoveDone |
| bool | latchArmMoveDone |
| bool | latchHandMoveDone |
| bool | handSeqTerminator |
| bool | fingersInPosition |
| std::deque< bool > | fingerInPosition |
| bool | configured |
| bool | closed |
| bool | checkEnabled |
| bool | tracking_mode |
| bool | torsoActive |
| bool | reachTmoEnabled |
| bool | locked |
| bool | verbose |
| double | default_exec_time |
| double | waitTmo |
| double | reachTmo |
| double | latchTimerWait |
| double | latchTimerReach |
| double | latchTimerReachLog |
| int | jHandMin |
| int | jHandMax |
| yarp::sig::Vector | enableTorsoSw |
| yarp::sig::Vector | disableTorsoSw |
| yarp::sig::Vector | curHandFinalPoss |
| yarp::sig::Vector | curHandTols |
| yarp::sig::Vector | curGraspDetectionThres |
| double | curHandTmo |
| double | latchTimerHand |
| std::vector< int > | fingersJnts |
| std::set< int > | fingersJntsSet |
| std::set< int > | fingersMovingJntsSet |
| std::multimap< int, int > | fingers2JntsMap |
| ActionPrimitivesCallback * | actionClb |
| yarp::os::PeriodicThread * | actionWP |
| iCub::action::ActionPrimitives::ActionsQueue | actionsQueue |
| std::map< std::string, std::deque< HandWayPoint > > | handSeqMap |
Detailed Description
A derived class defining a first abstraction layer on top of actionPrimitives father class.
It internally predeclares (without actually defining) a set of hand sequence motions key ("open_hand", "close_hand" and "karate_hand" :) that are used for grasp(), touch() and tap() actions.
- Note
- Given as an example of how primitive actions can be combined in higher level actions, thus how further layers can be inherited from the base class.
Definition at line 930 of file actionPrimitives.h.
Constructor & Destructor Documentation
◆ ActionPrimitivesLayer1() [1/2]
|
inline |
Default Constructor.
Definition at line 936 of file actionPrimitives.h.
◆ ActionPrimitivesLayer1() [2/2]
|
inline |
Constructor.
- Parameters
-
opt the Property used to configure the object after its creation.
Definition at line 943 of file actionPrimitives.h.
Member Function Documentation
◆ grasp()
|
virtual |
Grasp the given target (combined action).
- Parameters
-
x the 3-d target position [m]. o the 4-d hand orientation used while reaching/grasping (given in axis-angle representation: ax ay az angle in rad). d the displacement [m] wrt the target position that identifies a location to be reached prior to grasping.
- Returns
- true/false on success/fail.
- Note
- internal implementation (pseudo-code): ...pushAction(x,o);pushAction("close_hand");...virtual bool pushAction(const yarp::sig::Vector &x, const yarp::sig::Vector &o, const std::string &handSeqKey, const double execTime=ACTIONPRIM_DISABLE_EXECTIME, ActionPrimitivesCallback *clb=NULL)Insert a combination of arm and hand primitive actions in the actions queue.
It reachs for (x+d,o) opening the hand, then reachs for (x,o) and finally closes the hand.
Reimplemented in iCub::action::ActionPrimitivesLayer2.
Definition at line 2073 of file actionPrimitives.cpp.
◆ tap()
|
virtual |
Tap the given target (combined action).
- Parameters
-
x1 the fisrt 3-d target position [m]. o1 the first 4-d hand orientation (given in axis-angle representation: ax ay az angle in rad). x2 the second 3-d target position [m]. o2 the second 4-d hand orientation (given in axis-angle representation: ax ay az angle in rad). execTime the arm action execution time only while tapping [s] (to be specified iff different from default value).
- Returns
- true/false on success/fail.
- Note
- internal implementation (pseudo-code):
It reachs for (x1,o1), then reachs for (x2,o2) and then again for (x1,o1).
Definition at line 2108 of file actionPrimitives.cpp.
◆ touch()
|
virtual |
Touch the given target (combined action).
- Parameters
-
x the 3-d target position [m]. o the 4-d hand orientation used while reaching/touching (given in axis-angle representation: ax ay az angle in rad). d the displacement [m] wrt the target position that identifies a location to be reached prior to touching.
- Returns
- true/false on success/fail.
- Note
- internal implementation (pseudo-code):
It reachs for (x+d,o), then reachs for (x,o). Similar to grasp but without final hand action.
Reimplemented in iCub::action::ActionPrimitivesLayer2.
Definition at line 2091 of file actionPrimitives.cpp.
The documentation for this class was generated from the following files:
- icub-main/src/libraries/actionPrimitives/include/iCub/action/actionPrimitives.h
- icub-main/src/libraries/actionPrimitives/src/actionPrimitives.cpp
Generated on for iCub-main by
 1.15.0