iCub::ctrl::minJerkVelCtrl Class Referenceabstract
Abstract class for minimum-jerk controllers with velocity commands. More...
#include <minJerkCtrl.h>
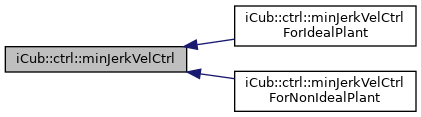
Inheritance diagram for iCub::ctrl::minJerkVelCtrl:
Public Member Functions | |
| virtual yarp::sig::Vector | computeCmd (const double _T, const yarp::sig::Vector &e)=0 |
| Computes the velocity command. | |
| virtual void | reset (const yarp::sig::Vector &u0)=0 |
| Resets the controller to a given value. | |
| virtual | ~minJerkVelCtrl () |
| Destructor. | |
Protected Member Functions | |
| virtual void | computeCoeffs ()=0 |
Detailed Description
Abstract class for minimum-jerk controllers with velocity commands.
Definition at line 46 of file minJerkCtrl.h.
Constructor & Destructor Documentation
◆ ~minJerkVelCtrl()
|
inlinevirtual |
Destructor.
Definition at line 70 of file minJerkCtrl.h.
Member Function Documentation
◆ computeCmd()
|
pure virtual |
Computes the velocity command.
- Parameters
-
_T the current execution time. e the error between the desired position and the feedback.
- Returns
- the velocity command.
Implemented in iCub::ctrl::minJerkVelCtrlForIdealPlant, and iCub::ctrl::minJerkVelCtrlForNonIdealPlant.
◆ computeCoeffs()
|
protectedpure virtual |
Implemented in iCub::ctrl::minJerkVelCtrlForIdealPlant, and iCub::ctrl::minJerkVelCtrlForNonIdealPlant.
◆ reset()
|
pure virtual |
Resets the controller to a given value.
- Parameters
-
u0 the initial output of the controller.
Implemented in iCub::ctrl::minJerkVelCtrlForIdealPlant, and iCub::ctrl::minJerkVelCtrlForNonIdealPlant.
The documentation for this class was generated from the following file:
- icub-main/src/libraries/ctrlLib/include/iCub/ctrl/minJerkCtrl.h
Generated on for iCub-main by
 1.15.0