math.h File Reference
#include <cmath>#include <yarp/sig/Vector.h>#include <yarp/sig/Matrix.h>#include <yarp/math/Math.h>Include dependency graph for math.h:
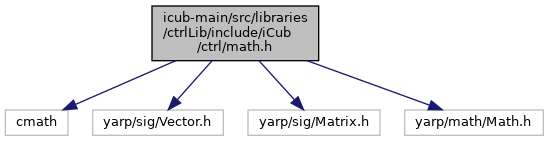
Go to the source code of this file.
Namespaces | |
| namespace | iCub |
| This file contains the definition of unique IDs for the body parts and the skin parts of the robot. | |
| namespace | iCub::ctrl |
Functions | |
| double | iCub::ctrl::dot (const yarp::sig::Matrix &A, int colA, const yarp::sig::Matrix &B, int colB) |
| Returns the dot product between two vectors given in the form: matrix(:,col). | |
| double | iCub::ctrl::norm2 (const yarp::sig::Matrix &M, int col) |
| Returns the squared norm of the vector given in the form: matrix(:,col). | |
| double | iCub::ctrl::norm (const yarp::sig::Matrix &M, int col) |
| Returns the norm of the vector given in the form: matrix(:,col). | |
| yarp::sig::Vector | iCub::ctrl::cross (const yarp::sig::Matrix &A, int colA, const yarp::sig::Matrix &B, int colB) |
| Returns the cross product between two vectors given in the form: matrix(:,col). | |
| yarp::sig::Vector | iCub::ctrl::Dcross (const yarp::sig::Vector &a, const yarp::sig::Vector &Da, const yarp::sig::Vector &b, const yarp::sig::Vector &Db) |
| Returns the derivatice of cross product between two vectors. | |
| yarp::sig::Vector | iCub::ctrl::Dcross (const yarp::sig::Matrix &A, const yarp::sig::Matrix &DA, int colA, const yarp::sig::Matrix &B, const yarp::sig::Matrix &DB, int colB) |
| Returns the derivative of cross product between two vectors given in the form: matrix(:,col). | |
Variables | |
| constexpr double | iCub::ctrl::CTRL_PI = M_PI |
| The PI constant. | |
| constexpr double | iCub::ctrl::CTRL_RAD2DEG = 180.0 / M_PI |
| 180/PI. | |
| constexpr double | iCub::ctrl::CTRL_DEG2RAD = M_PI / 180.0 |
| PI/180. | |
Generated on for iCub-main by
 1.15.0