|
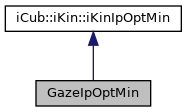
| | GazeIpOptMin (iKinChain &_chain, const double tol, const double constr_tol, const int max_iter=IKINCTRL_DISABLED, const unsigned int verbose=0) |
| void | set_ctrlPose (const unsigned int _ctrlPose) |
| bool | set_posePriority (const string &priority) |
| void | setHessianOpt (const bool useHessian) |
| Vector | solve (const Vector &q0, Vector &xd, const Vector &gDir) |
| | iKinIpOptMin (iKinChain &c, const unsigned int _ctrlPose, const double tol, const double constr_tol, const int max_iter=IKINCTRL_DISABLED, const unsigned int verbose=0, bool useHessian=true) |
| | Constructor.
|
| void | set_ctrlPose (const unsigned int _ctrlPose) |
| | Sets the state of Pose control settings.
|
| unsigned int | get_ctrlPose () const |
| | Returns the state of Pose control settings.
|
| bool | set_posePriority (const std::string &priority) |
| | Sets the Pose priority for weighting more either position or orientation while reaching in full pose.
|
| std::string | get_posePriority () const |
| | Returns the Pose priority settings.
|
| void | attachLIC (iKinLinIneqConstr &lic) |
| | Attach a iKinLinIneqConstr object in order to impose constraints of the form lB <= C*q <= uB.
|
| iKinLinIneqConstr & | getLIC () |
| | Returns a reference to the attached Linear Inequality Constraints object.
|
| void | specify2ndTaskEndEff (const unsigned int n) |
| | Selects the End-Effector of the 2nd task by giving the ordinal number n of last joint pointing at it.
|
| iKinChain & | get2ndTaskChain () |
| | Retrieves the 2nd task's chain.
|
| void | setMaxIter (const int max_iter) |
| | Sets Maximum Iteration.
|
| int | getMaxIter () const |
| | Retrieves the current value of Maximum Iteration.
|
| void | setMaxCpuTime (const double max_cpu_time) |
| | Sets Maximum CPU seconds.
|
| double | getMaxCpuTime () const |
| | Retrieves the current value of Maximum CPU seconds.
|
| void | setTol (const double tol) |
| | Sets cost function tolerance.
|
| double | getTol () const |
| | Retrieves cost function tolerance.
|
| void | setConstrTol (const double constr_tol) |
| | Sets constraints tolerance.
|
| double | getConstrTol () const |
| | Retrieves constraints tolerance.
|
| void | setVerbosity (const unsigned int verbose) |
| | Sets Verbosity.
|
| void | setHessianOpt (const bool useHessian) |
| | Selects whether to rely on exact Hessian computation or enable Quasi-Newton approximation (Hessian is enabled at start-up by default).
|
| void | setUserScaling (const bool useUserScaling, const double _obj_scaling, const double _x_scaling, const double _g_scaling) |
| | Enables/disables user scaling factors.
|
| void | setDerivativeTest (const bool enableTest, const bool enable2ndDer=false) |
| | Enable\disable derivative test at each call to solve method (disabled at start-up by default).
|
| void | getBoundsInf (double &lower, double &upper) |
| | Returns the lower and upper bounds to represent -inf and +inf.
|
| void | setBoundsInf (const double lower, const double upper) |
| | Sets the lower and upper bounds to represent -inf and +inf.
|
| virtual yarp::sig::Vector | solve (const yarp::sig::Vector &q0, yarp::sig::Vector &xd, double weight2ndTask, yarp::sig::Vector &xd_2nd, yarp::sig::Vector &w_2nd, double weight3rdTask, yarp::sig::Vector &qd_3rd, yarp::sig::Vector &w_3rd, int *exit_code=NULL, bool *exhalt=NULL, iKinIterateCallback *iterate=NULL) |
| | Executes the IpOpt algorithm trying to converge on target.
|
| virtual yarp::sig::Vector | solve (const yarp::sig::Vector &q0, yarp::sig::Vector &xd, double weight2ndTask, yarp::sig::Vector &xd_2nd, yarp::sig::Vector &w_2nd) |
| | Executes the IpOpt algorithm trying to converge on target.
|
| virtual yarp::sig::Vector | solve (const yarp::sig::Vector &q0, yarp::sig::Vector &xd) |
| | Executes the IpOpt algorithm trying to converge on target.
|
| virtual | ~iKinIpOptMin () |
| | Default destructor.
|
Definition at line 40 of file gazeNlp.h.
 1.15.0