clustering.cpp File Reference
#include <memory>#include <vector>#include <cmath>#include <yarp/math/Math.h>#include <iCub/ctrl/clustering.h>Include dependency graph for clustering.cpp:
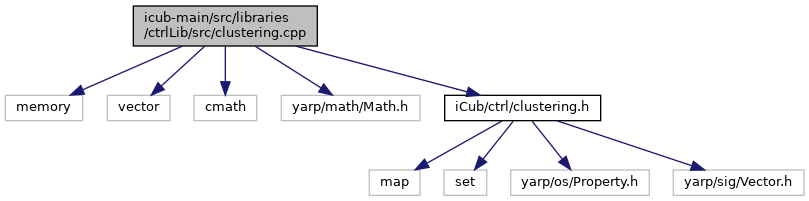
Go to the source code of this file.
Classes | |
| struct | iCub::ctrl::dbscan::Data_t |
| struct | iCub::ctrl::dbscan::Node_t |
| struct | iCub::ctrl::dbscan::Epsilon_neighbours_t |
Namespaces | |
| namespace | iCub |
| This file contains the definition of unique IDs for the body parts and the skin parts of the robot. | |
| namespace | iCub::ctrl |
| namespace | iCub::ctrl::dbscan |
Enumerations | |
| enum class | iCub::ctrl::dbscan::PointType { iCub::ctrl::dbscan::unclassified =-1 , iCub::ctrl::dbscan::noise =-2 } |
Functions | |
| shared_ptr< Node_t > | iCub::ctrl::dbscan::create_node (const size_t index) |
| void | iCub::ctrl::dbscan::append (const size_t index, shared_ptr< Epsilon_neighbours_t > en) |
| shared_ptr< Epsilon_neighbours_t > | iCub::ctrl::dbscan::get_epsilon_neighbours (const size_t index, shared_ptr< Data_t > augData) |
| void | iCub::ctrl::dbscan::spread (const size_t index, shared_ptr< Epsilon_neighbours_t > seeds, const size_t id, shared_ptr< Data_t > augData) |
| bool | iCub::ctrl::dbscan::expand (const size_t index, const size_t id, shared_ptr< Data_t > augData) |
Generated on for iCub-main by
 1.15.0