gravityCompensatorThread Class Reference
#include <gravityThread.h>
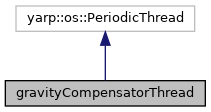
Inheritance diagram for gravityCompensatorThread:
Public Member Functions | |
| gravityCompensatorThread (std::string _wholeBodyName, int _rate, PolyDriver *_ddLA, PolyDriver *_ddRA, PolyDriver *_ddH, PolyDriver *_ddLL, PolyDriver *_ddRL, PolyDriver *_ddT, version_tag icub_type, bool _inertial_enabled) | |
| void | setZeroJntAngVelAcc () |
| bool | readAndUpdate (bool waitMeasure=false) |
| bool | getLowerEncodersSpeedAndAcceleration () |
| bool | getUpperEncodersSpeedAndAcceleration () |
| bool | threadInit () override |
| void | feedFwdGravityControl (int part_ctrlJnt, const std::string &s_part, IControlMode *iCtrlMode, ITorqueControl *iTqs, IImpedanceControl *iImp, IInteractionMode *iIntMode, const Vector &command, bool releasing=false) |
| void | run () override |
| void | threadRelease () override |
| thread_status_enum | getThreadStatus () |
Public Attributes | |
| int | gravity_mode |
| int | external_mode |
Detailed Description
Definition at line 45 of file gravityThread.h.
Constructor & Destructor Documentation
◆ gravityCompensatorThread()
| gravityCompensatorThread::gravityCompensatorThread | ( | std::string | _wholeBodyName, |
| int | _rate, | ||
| PolyDriver * | _ddLA, | ||
| PolyDriver * | _ddRA, | ||
| PolyDriver * | _ddH, | ||
| PolyDriver * | _ddLL, | ||
| PolyDriver * | _ddRL, | ||
| PolyDriver * | _ddT, | ||
| version_tag | icub_type, | ||
| bool | _inertial_enabled ) |
Definition at line 189 of file gravityThread.cpp.
Member Function Documentation
◆ feedFwdGravityControl()
| void gravityCompensatorThread::feedFwdGravityControl | ( | int | part_ctrlJnt, |
| const std::string & | s_part, | ||
| IControlMode * | iCtrlMode, | ||
| ITorqueControl * | iTqs, | ||
| IImpedanceControl * | iImp, | ||
| IInteractionMode * | iIntMode, | ||
| const Vector & | command, | ||
| bool | releasing = false ) |
Definition at line 575 of file gravityThread.cpp.
◆ getLowerEncodersSpeedAndAcceleration()
| bool gravityCompensatorThread::getLowerEncodersSpeedAndAcceleration | ( | ) |
Definition at line 343 of file gravityThread.cpp.
◆ getThreadStatus()
|
inline |
Definition at line 180 of file gravityThread.h.
◆ getUpperEncodersSpeedAndAcceleration()
| bool gravityCompensatorThread::getUpperEncodersSpeedAndAcceleration | ( | ) |
Definition at line 403 of file gravityThread.cpp.
◆ readAndUpdate()
| bool gravityCompensatorThread::readAndUpdate | ( | bool | waitMeasure = false | ) |
Definition at line 274 of file gravityThread.cpp.
◆ run()
|
override |
Definition at line 652 of file gravityThread.cpp.
◆ setZeroJntAngVelAcc()
| void gravityCompensatorThread::setZeroJntAngVelAcc | ( | ) |
Definition at line 257 of file gravityThread.cpp.
◆ threadInit()
|
override |
Definition at line 462 of file gravityThread.cpp.
◆ threadRelease()
|
override |
Definition at line 909 of file gravityThread.cpp.
Member Data Documentation
◆ external_mode
| int gravityCompensatorThread::external_mode |
Definition at line 167 of file gravityThread.h.
◆ gravity_mode
| int gravityCompensatorThread::gravity_mode |
Definition at line 166 of file gravityThread.h.
The documentation for this class was generated from the following files:
- icub-main/src/modules/gravityCompensator/gravityThread.h
- icub-main/src/modules/gravityCompensator/gravityThread.cpp
Generated on for iCub-main by
 1.15.0