CouplingICubHandMk2 Class Reference
TBD. More...
#include <CouplingICubHandMk2.h>
Inheritance diagram for CouplingICubHandMk2:
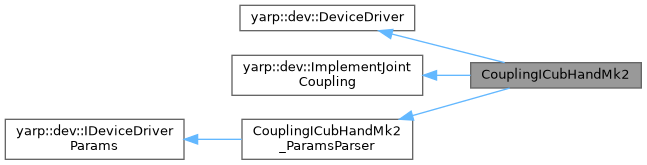
Public Member Functions | |
| CouplingICubHandMk2 ()=default | |
| virtual | ~CouplingICubHandMk2 () override=default |
| bool | convertFromPhysicalJointsToActuatedAxesPos (const yarp::sig::Vector &physJointsPos, yarp::sig::Vector &actAxesPos) override |
| bool | convertFromPhysicalJointsToActuatedAxesVel (const yarp::sig::Vector &physJointsPos, const yarp::sig::Vector &physJointsVel, yarp::sig::Vector &actAxesVel) override |
| bool | convertFromPhysicalJointsToActuatedAxesAcc (const yarp::sig::Vector &physJointsPos, const yarp::sig::Vector &physJointsVel, const yarp::sig::Vector &physJointsAcc, yarp::sig::Vector &actAxesAcc) override |
| bool | convertFromPhysicalJointsToActuatedAxesTrq (const yarp::sig::Vector &physJointsPos, const yarp::sig::Vector &physJointsTrq, yarp::sig::Vector &actAxesTrq) override |
| bool | convertFromActuatedAxesToPhysicalJointsPos (const yarp::sig::Vector &actAxesPos, yarp::sig::Vector &physJointsPos) override |
| bool | convertFromActuatedAxesToPhysicalJointsVel (const yarp::sig::Vector &actAxesPos, const yarp::sig::Vector &actAxesVel, yarp::sig::Vector &physJointsVel) override |
| bool | convertFromActuatedAxesToPhysicalJointsAcc (const yarp::sig::Vector &actAxesPos, const yarp::sig::Vector &actAxesVel, const yarp::sig::Vector &actAxesAcc, yarp::sig::Vector &physJointsAcc) override |
| bool | convertFromActuatedAxesToPhysicalJointsTrq (const yarp::sig::Vector &actAxesPos, const yarp::sig::Vector &actAxesTrq, yarp::sig::Vector &physJointsTrq) override |
| bool | open (yarp::os::Searchable &config) override |
| Configure with a set of options. | |
| Public Member Functions inherited from CouplingICubHandMk2_ParamsParser | |
| CouplingICubHandMk2_ParamsParser () | |
| ~CouplingICubHandMk2_ParamsParser () override=default | |
| bool | parseParams (const yarp::os::Searchable &config) override |
| std::string | getDeviceClassName () const override |
| std::string | getDeviceName () const override |
| std::string | getDocumentationOfDeviceParams () const override |
| std::vector< std::string > | getListOfParams () const override |
| bool | getParamValue (const std::string ¶mName, std::string ¶mValue) const override |
| std::string | getConfiguration () const override |
Additional Inherited Members | |
| Public Attributes inherited from CouplingICubHandMk2_ParamsParser | |
| const std::string | m_device_classname = {"CouplingICubHandMk2"} |
| const std::string | m_device_name = {"couplingICubHandMk2"} |
| bool | m_parser_is_strict = false |
| const parser_version_type | m_parser_version = {} |
| std::string | m_provided_configuration |
| const std::string | m_jointNames_defaultValue = {""} |
| const std::string | m_LIMITS_jntPosMin_defaultValue = {""} |
| const std::string | m_LIMITS_jntPosMax_defaultValue = {""} |
| const std::string | m_COUPLING_actuatedAxesNames_defaultValue = {""} |
| const std::string | m_COUPLING_actuatedAxesPosMin_defaultValue = {""} |
| const std::string | m_COUPLING_actuatedAxesPosMax_defaultValue = {""} |
| std::vector< std::string > | m_jointNames = {} |
| std::vector< double > | m_LIMITS_jntPosMin = {} |
| std::vector< double > | m_LIMITS_jntPosMax = {} |
| std::vector< std::string > | m_COUPLING_actuatedAxesNames = {} |
| std::vector< double > | m_COUPLING_actuatedAxesPosMin = {} |
| std::vector< double > | m_COUPLING_actuatedAxesPosMax = {} |
Detailed Description
TBD.
Definition at line 41 of file CouplingICubHandMk2.h.
Constructor & Destructor Documentation
◆ CouplingICubHandMk2()
|
default |
◆ ~CouplingICubHandMk2()
|
overridevirtualdefault |
Member Function Documentation
◆ convertFromActuatedAxesToPhysicalJointsAcc()
|
override |
Definition at line 258 of file CouplingICubHandMk2.cpp.
◆ convertFromActuatedAxesToPhysicalJointsPos()
|
override |
Definition at line 149 of file CouplingICubHandMk2.cpp.
◆ convertFromActuatedAxesToPhysicalJointsTrq()
|
override |
Definition at line 311 of file CouplingICubHandMk2.cpp.
◆ convertFromActuatedAxesToPhysicalJointsVel()
|
override |
Definition at line 204 of file CouplingICubHandMk2.cpp.
◆ convertFromPhysicalJointsToActuatedAxesAcc()
|
override |
Definition at line 114 of file CouplingICubHandMk2.cpp.
◆ convertFromPhysicalJointsToActuatedAxesPos()
|
override |
Definition at line 52 of file CouplingICubHandMk2.cpp.
◆ convertFromPhysicalJointsToActuatedAxesTrq()
|
override |
Definition at line 144 of file CouplingICubHandMk2.cpp.
◆ convertFromPhysicalJointsToActuatedAxesVel()
|
override |
Definition at line 83 of file CouplingICubHandMk2.cpp.
◆ open()
|
override |
Configure with a set of options.
- Parameters
-
config The options to use
- Returns
- true iff the object could be configured.
Definition at line 36 of file CouplingICubHandMk2.cpp.
The documentation for this class was generated from the following files:
- icub-main/src/libraries/icubmod/couplingICubHandMk2/CouplingICubHandMk2.h
- icub-main/src/libraries/icubmod/couplingICubHandMk2/CouplingICubHandMk2.cpp
Generated on for iCub-main by
 1.15.0