iCub::iDyn::iCubLegSensorLink Class Reference
A class for setting a virtual sensor link on the iCub leg, for the leg FT sensor. More...
#include <iDynInv.h>
Inheritance diagram for iCub::iDyn::iCubLegSensorLink:
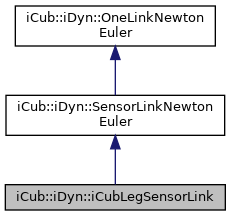
Public Member Functions | |
| iCubLegSensorLink (const std::string _type, const NewEulMode _mode=DYNAMIC, unsigned int verb=iCub::skinDynLib::NO_VERBOSE) | |
| Constructor: the sensor parameters are automatically set with "right" or "left" choice. | |
| virtual | ~iCubLegSensorLink () |
| Destructor. | |
| std::string | getType () const |
| Public Member Functions inherited from iCub::iDyn::SensorLinkNewtonEuler | |
| SensorLinkNewtonEuler (const NewEulMode _mode, unsigned int verb=iCub::skinDynLib::NO_VERBOSE) | |
| Default constructor. | |
| SensorLinkNewtonEuler (const yarp::sig::Matrix &_H, const yarp::sig::Matrix &_COM, const double _m, const yarp::sig::Matrix &_I, const NewEulMode _mode, unsigned int verb=iCub::skinDynLib::NO_VERBOSE) | |
| Constructor. | |
| virtual | ~SensorLinkNewtonEuler () |
| Destructor. | |
| bool | setMeasuredFMu (const yarp::sig::Vector &_F, const yarp::sig::Vector &_Mu) |
| Set the sensor measured force/moment - if measured by a FT sensor. | |
| bool | setSensor (const yarp::sig::Matrix &_H, const yarp::sig::Matrix &_HC, const double _m, const yarp::sig::Matrix &_I) |
| Set a new sensor or new sensor properties. | |
| void | ForwardAttachToLink (iDynLink *link) |
| Compute w,dw,ddp,dppC given the reference frame of the link where the sensor is. | |
| void | BackwardAttachToLink (iDynLink *link) |
| Compute F,Mu given the reference frame of the link where the sensor is. | |
| void | ForwardForcesMomentsToLink (iDynLink *link) |
| Forward the sensor forces and moments, measured by the sensor, to the reference frame of the link where the sensor is: this method is the base for the inverse Newton-Euler algorithm, since it forwards the sensor measurements to the iDynChain. | |
| yarp::sig::Vector | getForceMoment () const |
| Get the sensor force and moment in a single (6x1) vector. | |
| const yarp::sig::Vector & | getAngVel () const |
| const yarp::sig::Vector & | getAngAcc () const |
| const yarp::sig::Vector & | getLinAcc () const |
| const yarp::sig::Vector & | getLinAccC () const |
| const yarp::sig::Vector & | getForce () const |
| const yarp::sig::Vector & | getMoment (bool isBase=false) const |
| double | getIm () const |
| double | getFs () const |
| double | getFv () const |
| double | getD2q () const |
| double | getDq () const |
| double | getKr () const |
| const yarp::sig::Vector & | getAngAccM () const |
| double | getTorque () const |
| const yarp::sig::Matrix & | getH () const |
| double | getMass () const |
| const yarp::sig::Matrix & | getInertia () const |
| const yarp::sig::Matrix & | getR () |
| const yarp::sig::Matrix & | getRC () |
| const yarp::sig::Vector & | getr (bool proj=false) |
| const yarp::sig::Vector & | getrC (bool proj=false) |
| bool | setForce (const yarp::sig::Vector &_F) |
| Set the OneLink force: either the corresponding iDynLink force, or the one declared as member in the child classes derived from OneLink, such as SensorLink. | |
| bool | setMoment (const yarp::sig::Vector &_Mu) |
| Set the OneLink moment: either the corresponding iDynLink moment, or the one declared as member in the child classes derived from OneLink, such as SensorLink. | |
| void | setTorque (const double _Tau) |
| Set the OneLink torque, ie the corresponding iDynLink joint torque (nothing in the child classes derived from OneLink, such as SensorLink). | |
| bool | setAngVel (const yarp::sig::Vector &_w) |
| Set the OneLink angular velocity (w), ie the corresponding iDynLink angular velocity (w) (in the child classes derived from OneLink, it depends). | |
| bool | setAngAcc (const yarp::sig::Vector &_dw) |
| Set the OneLink angular acceleration (dw), ie the corresponding iDynLink angular acceleration (dw) (in the child classes derived from OneLink, it depends). | |
| bool | setLinAcc (const yarp::sig::Vector &_ddp) |
| Set the OneLink linear acceleration (ddp), ie the corresponding iDynLink linear acceleration (ddp) (in the child classes derived from OneLink, it depends). | |
| bool | setLinAccC (const yarp::sig::Vector &_ddpC) |
| Set the OneLink linear acceleration of the COM (ddpC), ie the corresponding iDynLink linear acceleration of the COM (ddpC) (nothing in the child classes derived from OneLink, except for SensorLink). | |
| bool | setAngAccM (const yarp::sig::Vector &_dwM) |
| Set the OneLink angular acceleration of the motor (dwM), ie the corresponding iDynLink angular acceleration of the COM (dwM) (nothing in the child classes derived from OneLink). | |
| std::string | toString () const |
| Useful to print some information. | |
| void | computeAngVel (iDynLink *link) |
| void | computeAngAcc (iDynLink *link) |
| void | computeLinAcc (iDynLink *link) |
| void | computeLinAccC () |
| void | computeForce (iDynLink *link) |
| void | computeMoment (iDynLink *link) |
| void | computeForceToLink (iDynLink *link) |
| void | computeMomentToLink (iDynLink *link) |
| Public Member Functions inherited from iCub::iDyn::OneLinkNewtonEuler | |
| OneLinkNewtonEuler (iDyn::iDynLink *dlink=NULL) | |
| Default constructor. | |
| OneLinkNewtonEuler (const NewEulMode _mode, unsigned int verb=iCub::skinDynLib::NO_VERBOSE, iDyn::iDynLink *dlink=NULL) | |
| Constructor, with initialization of some data. | |
| virtual | ~OneLinkNewtonEuler () |
| Destructor. | |
| void | zero () |
| Set everything to zero; R is set to an identity matrix. | |
| virtual bool | setAsBase (const yarp::sig::Vector &_w, const yarp::sig::Vector &_dw, const yarp::sig::Vector &_ddp) |
| Virtual method to set the frame as the base one: this is useful to initialize the forward phase of Newton-Euler's method. | |
| virtual bool | setAsBase (const yarp::sig::Vector &_F, const yarp::sig::Vector &_Mu) |
| virtual bool | setAsFinal (const yarp::sig::Vector &_F, const yarp::sig::Vector &_Mu) |
| Set the frame as the final one: this is useful to initialize the backward phase of Newton-Euler's method, by setting F and Mu; R is an identity matrix. | |
| virtual bool | setAsFinal (const yarp::sig::Vector &_w, const yarp::sig::Vector &_dw, const yarp::sig::Vector &_ddp) |
| Set the frame as the final one: this is useful to initialize the backward phase of Euler's method, by setting w, dw and ddp; R is an identity matrix. | |
| virtual bool | setMeasuredTorque (const double _Tau) |
| Set measured torque in a joint torque sensor frame. | |
| void | setVerbose (unsigned int verb=iCub::skinDynLib::VERBOSE) |
| Set the verbosity level of comments during operations. | |
| void | setMode (const NewEulMode _mode) |
| Set the operation mode (static,dynamic etc). | |
| bool | setZM (const yarp::sig::Vector &_zm) |
| Set the zM vector. | |
| void | setInfo (const std::string &_info) |
| Set some information about this OneLink class. | |
| NewEulMode | getMode () const |
| yarp::sig::Vector | getZM () const |
| std::string | getInfo () const |
| virtual const yarp::sig::Matrix & | getH () |
| void | ForwardKinematics (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] Compute w, dw, ddp, ddpC, dwM | |
| void | BackwardKinematics (OneLinkNewtonEuler *prev) |
| [Backward Kinematic computation] Compute w, dw, ddp, ddpC, dwM | |
| void | BackwardWrench (OneLinkNewtonEuler *next) |
| [Backward Newton-Euler] Compute F, Mu, Tau | |
| void | ForwardWrench (OneLinkNewtonEuler *prev) |
| [Inverse Newton-Euler] Compute F, Mu, Tau | |
| virtual void | computeTorque (OneLinkNewtonEuler *prev) |
| [all] Compute joint torque; moment must be pre-computed | |
Protected Attributes | |
| std::string | type |
| the leg type: left/right | |
| Protected Attributes inherited from iCub::iDyn::SensorLinkNewtonEuler | |
| yarp::sig::Vector | F |
| measured or estimated force | |
| yarp::sig::Vector | Mu |
| measured or estimated moment | |
| yarp::sig::Vector | w |
| angular velocity | |
| yarp::sig::Vector | dw |
| angular acceleration | |
| yarp::sig::Vector | ddp |
| linear acceleration | |
| yarp::sig::Vector | ddpC |
| linear acceleration of the COM | |
| yarp::sig::Matrix | H |
| the roto-translational matrix from the i-th link to the sensor: it's the matrix describing the sensor position and orientation with respect to the frame of the link where the sensor is placed on | |
| yarp::sig::Matrix | COM |
| the roto-translational matrix of the COM of the semi-link (bewteen sensor and ith link frame) | |
| yarp::sig::Matrix | I |
| the semi-link inertia | |
| double | m |
| the semi-link mass (the portion of link defined by the sensor) | |
| yarp::sig::Matrix | R |
| yarp::sig::Matrix | RC |
| yarp::sig::Vector | r |
| yarp::sig::Vector | r_proj |
| yarp::sig::Vector | rc |
| yarp::sig::Vector | rc_proj |
| const yarp::sig::Vector | zeros0 |
| Protected Attributes inherited from iCub::iDyn::OneLinkNewtonEuler | |
| NewEulMode | mode |
| STATIC/DYNAMIC/DYNAMIC_W_ROTOR/DYNAMIC_CORIOLIS_GRAVITY. | |
| std::string | info |
| info or useful notes | |
| unsigned int | verbose |
| verbosity flag | |
| yarp::sig::Vector | z0 |
| z0=[0 0 1]' | |
| yarp::sig::Vector | zm |
| z^{i-1}_{m_{i}} versor rotating solidally with link i, projected in frame i ==>> constant | |
| iDyn::iDynLink * | link |
| the corresponding iDynLink | |
Additional Inherited Members | |
| Protected Member Functions inherited from iCub::iDyn::OneLinkNewtonEuler | |
| void | computeAngVel (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] compute angular velocity of the link | |
| void | computeAngVelBackward (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] compute angular velocity of the previous link frame | |
| void | computeAngAcc (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] compute angular acceleration of the link | |
| void | computeAngAccBackward (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] compute angular acceleration of the previous link frame | |
| void | computeLinAcc (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] compute linear acceleration of the reference frame of the link | |
| void | computeLinAccBackward (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] compute linear acceleration of the reference frame of the previous link | |
| void | computeLinAccC () |
| [Forward Newton-Euler] compute linear acceleration of the center of mass | |
| void | computeAngAccM (OneLinkNewtonEuler *prev) |
| [Forward Newton-Euler] compute angular acceleration of the rotor | |
| void | computeForceBackward (OneLinkNewtonEuler *next) |
| [Backward Newton-Euler] compute force from the following link | |
| void | computeForceForward (OneLinkNewtonEuler *prev) |
| [Inverse Newton-Euler] compute force from the previous link | |
| void | computeMomentBackward (OneLinkNewtonEuler *next) |
| [Backward Newton-Euler] compute moment from the following link | |
| void | computeMomentForward (OneLinkNewtonEuler *prev) |
| [Inverse Newton-Euler] compute moment from the previous link | |
Detailed Description
A class for setting a virtual sensor link on the iCub leg, for the leg FT sensor.
The parameters are automatically set after choosing "left" or "right" part. By default, the CAD parameters are set.
Constructor & Destructor Documentation
◆ iCubLegSensorLink()
| iCubLegSensorLink::iCubLegSensorLink | ( | const std::string | _type, |
| const NewEulMode | _mode = DYNAMIC, | ||
| unsigned int | verb = iCub::skinDynLib::NO_VERBOSE ) |
Constructor: the sensor parameters are automatically set with "right" or "left" choice.
- Parameters
-
_type a string "left"/"right" _mode the analysis mode (STATIC/DYNAMIC) verb flag for verbosity
Definition at line 2460 of file iDynInv.cpp.
◆ ~iCubLegSensorLink()
|
inlinevirtual |
Member Function Documentation
◆ getType()
|
virtual |
- Returns
- type the leg type: left/right
Reimplemented from iCub::iDyn::SensorLinkNewtonEuler.
Definition at line 2498 of file iDynInv.cpp.
Member Data Documentation
◆ type
|
protected |
The documentation for this class was generated from the following files:
- icub-main/src/libraries/iDyn/include/iCub/iDyn/iDynInv.h
- icub-main/src/libraries/iDyn/src/iDynInv.cpp
Generated on for iCub-main by
 1.15.0