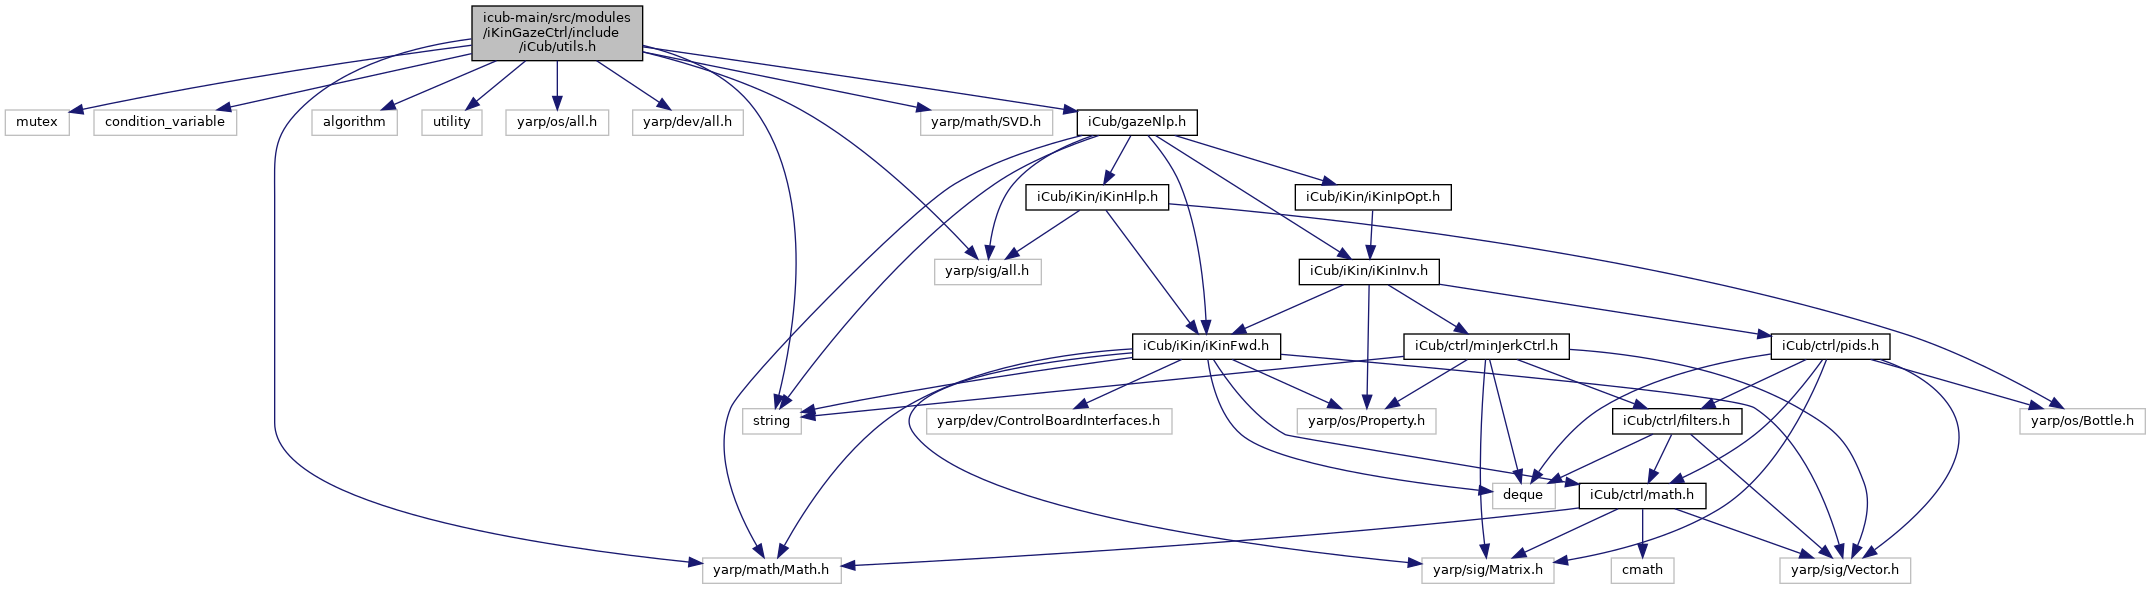
#include <mutex>
#include <condition_variable>
#include <string>
#include <algorithm>
#include <utility>
#include <yarp/os/all.h>
#include <yarp/dev/all.h>
#include <yarp/sig/all.h>
#include <yarp/math/Math.h>
#include <yarp/math/SVD.h>
#include <iCub/gazeNlp.h>
Go to the source code of this file.
|
| double | sat (const double val, const double min, const double max) |
| bool | getCamParams (const ResourceFinder &rf, const string &type, Matrix **Prj, int &w, int &h, const bool verbose=false) |
| bool | getAlignHN (const ResourceFinder &rf, const string &type, iKinChain *chain, const bool verbose=false) |
| Matrix | alignJointsBounds (iKinChain *chain, PolyDriver *drvTorso, PolyDriver *drvHead, const ExchangeData *commData) |
| void | copyJointsBounds (iKinChain *ch1, iKinChain *ch2) |
| void | updateTorsoBlockedJoints (iKinChain *chain, const Vector &fbTorso) |
| void | updateNeckBlockedJoints (iKinChain *chain, const Vector &fbNeck) |
| bool | getFeedback (Vector &fbTorso, Vector &fbHead, PolyDriver *drvTorso, PolyDriver *drvHead, const ExchangeData *commData, double *timeStamp=nullptr) |
◆ alignJointsBounds()
| Matrix alignJointsBounds |
( |
iKinChain * | chain, |
|
|
PolyDriver * | drvTorso, |
|
|
PolyDriver * | drvHead, |
|
|
const ExchangeData * | commData ) |
◆ copyJointsBounds()
◆ getAlignHN()
| bool getAlignHN |
( |
const ResourceFinder & | rf, |
|
|
const string & | type, |
|
|
iKinChain * | chain, |
|
|
const bool | verbose = false ) |
◆ getCamParams()
| bool getCamParams |
( |
const ResourceFinder & | rf, |
|
|
const string & | type, |
|
|
Matrix ** | Prj, |
|
|
int & | w, |
|
|
int & | h, |
|
|
const bool | verbose = false ) |
◆ getFeedback()
| bool getFeedback |
( |
Vector & | fbTorso, |
|
|
Vector & | fbHead, |
|
|
PolyDriver * | drvTorso, |
|
|
PolyDriver * | drvHead, |
|
|
const ExchangeData * | commData, |
|
|
double * | timeStamp = nullptr ) |
◆ sat()
| double sat |
( |
const double | val, |
|
|
const double | min, |
|
|
const double | max ) |
|
inline |
◆ updateNeckBlockedJoints()
| void updateNeckBlockedJoints |
( |
iKinChain * | chain, |
|
|
const Vector & | fbNeck ) |
◆ updateTorsoBlockedJoints()
| void updateTorsoBlockedJoints |
( |
iKinChain * | chain, |
|
|
const Vector & | fbTorso ) |
 1.15.0